Welcome to Journal of Automotive Safety and Energy,

Journal of Automotive Safety and Energy ›› 2025, Vol. 16 ›› Issue (2): 303-314.DOI: 10.3969/j.issn.1674-8484.2025.02.014
• Intelligent Driving and Intelligent Transportation • Previous Articles Next Articles
ZHANG Shuo1( ), LI Xiao1, CHEN Yisong1,*(), ZHAO Xuan1, YU Qiang1, YU Man2
Received:2024-07-16
Revised:2024-09-13
Online:2025-04-30
Published:2025-04-22
CLC Number:
ZHANG Shuo, LI Xiao, CHEN Yisong, ZHAO Xuan, YU Qiang, YU Man. Research on adaptive trajectory tracking control method for intelligent vehicle[J]. Journal of Automotive Safety and Energy, 2025, 16(2): 303-314.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.journalase.com/EN/10.3969/j.issn.1674-8484.2025.02.014
| 预测时域 | 8~29 |
|---|---|
| 控制时域 | 2 |
| 采样周期 | 0.02 s |
| 前轮转角控制量 | -δf, max~δf, max |
| 前轮转角控制增量 | -0.847°~0.847° |
| Q | |
| R | 100 |
| ρ | 1 000 |
| 预测时域 | 8~29 |
|---|---|
| 控制时域 | 2 |
| 采样周期 | 0.02 s |
| 前轮转角控制量 | -δf, max~δf, max |
| 前轮转角控制增量 | -0.847°~0.847° |
| Q | |
| R | 100 |
| ρ | 1 000 |
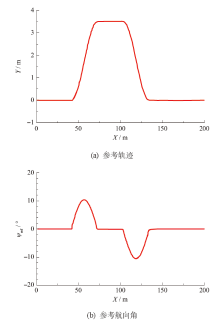
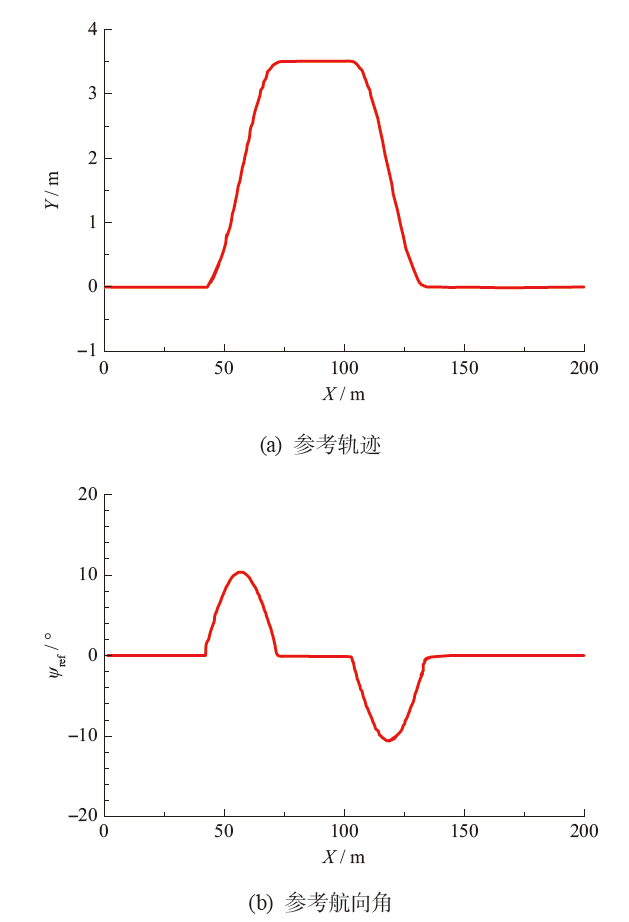
| Np | 轨迹跟踪 的有效性 | |Ed|max m | |Eψ|max (°) | |β|max (°) | |ω|max [(°)·s-1] | |
|---|---|---|---|---|---|---|
| 60,0.8 | 8 | 有效 | 0.071 7 | 0.759 4 | 1.528 3 | 21.081 7 |
| 15 | 有效 | 0.158 5 | 1.573 0 | 1.243 7 | 16.964 6 | |
| 22 | 有效 | 0.345 2 | 2.484 5 | 0.746 5 | 12.401 3 | |
| 29 | 有效 | 0.479 5 | 2.885 2 | 0.583 4 | 10.172 7 | |
| 60,0.3 | 8 | 失败 | - | - | - | - |
| 15 | 失败 | - | - | - | - | |
| 22 | 有效 | 0.362 2 | 2.221 0 | 1.682 0 | 11.935 5 | |
| 29 | 有效 | 0.545 7 | 3.021 0 | 0.727 2 | 10.250 6 | |
| 30,0.8 | 8 | 有效 | 0.065 5 | 2.495 3 | 0.870 8 | 8.552 3 |
| 15 | 有效 | 0.126 2 | 2.767 0 | 0.765 4 | 7.534 6 | |
| 22 | 有效 | 0.257 2 | 3.333 1 | 0.657 3 | 6.512 1 | |
| 29 | 有效 | 0.421 9 | 3.851 4 | 0.536 8 | 5.370 4 | |
| 30,0.3 | 8 | 有效 | 0.040 1 | 2.394 0 | 0.909 1 | 8.307 0 |
| 15 | 有效 | 0.123 9 | 2.821 2 | 0.820 4 | 7.530 1 | |
| 22 | 有效 | 0.250 5 | 3.364 2 | 0.814 9 | 7.477 1 | |
| 29 | 有效 | 0.468 7 | 3.857 2 | 0.571 6 | 5.256 1 |
| Np | 轨迹跟踪 的有效性 | |Ed|max m | |Eψ|max (°) | |β|max (°) | |ω|max [(°)·s-1] | |
|---|---|---|---|---|---|---|
| 60,0.8 | 8 | 有效 | 0.071 7 | 0.759 4 | 1.528 3 | 21.081 7 |
| 15 | 有效 | 0.158 5 | 1.573 0 | 1.243 7 | 16.964 6 | |
| 22 | 有效 | 0.345 2 | 2.484 5 | 0.746 5 | 12.401 3 | |
| 29 | 有效 | 0.479 5 | 2.885 2 | 0.583 4 | 10.172 7 | |
| 60,0.3 | 8 | 失败 | - | - | - | - |
| 15 | 失败 | - | - | - | - | |
| 22 | 有效 | 0.362 2 | 2.221 0 | 1.682 0 | 11.935 5 | |
| 29 | 有效 | 0.545 7 | 3.021 0 | 0.727 2 | 10.250 6 | |
| 30,0.8 | 8 | 有效 | 0.065 5 | 2.495 3 | 0.870 8 | 8.552 3 |
| 15 | 有效 | 0.126 2 | 2.767 0 | 0.765 4 | 7.534 6 | |
| 22 | 有效 | 0.257 2 | 3.333 1 | 0.657 3 | 6.512 1 | |
| 29 | 有效 | 0.421 9 | 3.851 4 | 0.536 8 | 5.370 4 | |
| 30,0.3 | 8 | 有效 | 0.040 1 | 2.394 0 | 0.909 1 | 8.307 0 |
| 15 | 有效 | 0.123 9 | 2.821 2 | 0.820 4 | 7.530 1 | |
| 22 | 有效 | 0.250 5 | 3.364 2 | 0.814 9 | 7.477 1 | |
| 29 | 有效 | 0.468 7 | 3.857 2 | 0.571 6 | 5.256 1 |
| Input:原始数据集 X = {x1, x2, …, xn} Process: 1. 对原始数据集中的指标属性同向化 X' 2. 构造向量归一化后的标准化矩阵Z = {z1, z2, …, zn} 3. for Z 的每一列Zi do 4. 最劣方案Z -的第i维度 ← Zi元素最小值 5. 最优方案Z +的第i维度 ← Zi元素最大值 6. end for 7. for zi∈Z do 8. zi与最优方案的接近程度Di+ 9. zi与最劣方案的接近程度Di- 10. zi与最优方案的贴近程度Ci 11. end for 12. 根据Ci大小进行排序 Output 各数据样本TOPSIS评价结果 |
| Input:原始数据集 X = {x1, x2, …, xn} Process: 1. 对原始数据集中的指标属性同向化 X' 2. 构造向量归一化后的标准化矩阵Z = {z1, z2, …, zn} 3. for Z 的每一列Zi do 4. 最劣方案Z -的第i维度 ← Zi元素最小值 5. 最优方案Z +的第i维度 ← Zi元素最大值 6. end for 7. for zi∈Z do 8. zi与最优方案的接近程度Di+ 9. zi与最劣方案的接近程度Di- 10. zi与最优方案的贴近程度Ci 11. end for 12. 根据Ci大小进行排序 Output 各数据样本TOPSIS评价结果 |
| vx (km·h-1) | Np | Si, max | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|
| μ = 0.1 | 0.3 | 0.5 | 0.7 | 0.9 | μ = 0.1 | 0.3 | 0.5 | 0.7 | 0.9 | ||
| 10 | 8 | 8 | 8 | 8 | 8 | 0.138 9 | 0.140 8 | 0.141 2 | 0.142 7 | 0.143 6 | |
| 30 | 14 | 11 | 11 | 11 | 8 | 0.164 1 | 0.152 1 | 0.158 1 | 0.152 2 | 0.154 3 | |
| 40 | 29 | 14 | 14 | 11 | 8 | 0.451 2 | 0.158 7 | 0.160 2 | 0.164 4 | 0.158 9 | |
| 50 | 20 | 14 | 14 | 11 | 0.180 3 | 0.169 3 | 0.167 5 | 0.164 9 | |||
| 60 | 29 | 23 | 20 | 17 | 0.365 1 | 0.313 3 | 0.186 3 | 0.173 1 | |||
| 90 | 29 | 26 | 20 | 1.000 0 | 0.269 9 | 0.203 3 | |||||
| 110 | 29 | 26 | 0.410 1 | 0.550 1 | |||||||
| 120 | 29 | 29 | 0.605 5 | 1.000 0 | |||||||
| vx (km·h-1) | Np | Si, max | |||||||||
|---|---|---|---|---|---|---|---|---|---|---|---|
| μ = 0.1 | 0.3 | 0.5 | 0.7 | 0.9 | μ = 0.1 | 0.3 | 0.5 | 0.7 | 0.9 | ||
| 10 | 8 | 8 | 8 | 8 | 8 | 0.138 9 | 0.140 8 | 0.141 2 | 0.142 7 | 0.143 6 | |
| 30 | 14 | 11 | 11 | 11 | 8 | 0.164 1 | 0.152 1 | 0.158 1 | 0.152 2 | 0.154 3 | |
| 40 | 29 | 14 | 14 | 11 | 8 | 0.451 2 | 0.158 7 | 0.160 2 | 0.164 4 | 0.158 9 | |
| 50 | 20 | 14 | 14 | 11 | 0.180 3 | 0.169 3 | 0.167 5 | 0.164 9 | |||
| 60 | 29 | 23 | 20 | 17 | 0.365 1 | 0.313 3 | 0.186 3 | 0.173 1 | |||
| 90 | 29 | 26 | 20 | 1.000 0 | 0.269 9 | 0.203 3 | |||||
| 110 | 29 | 26 | 0.410 1 | 0.550 1 | |||||||
| 120 | 29 | 29 | 0.605 5 | 1.000 0 | |||||||
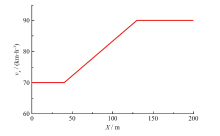
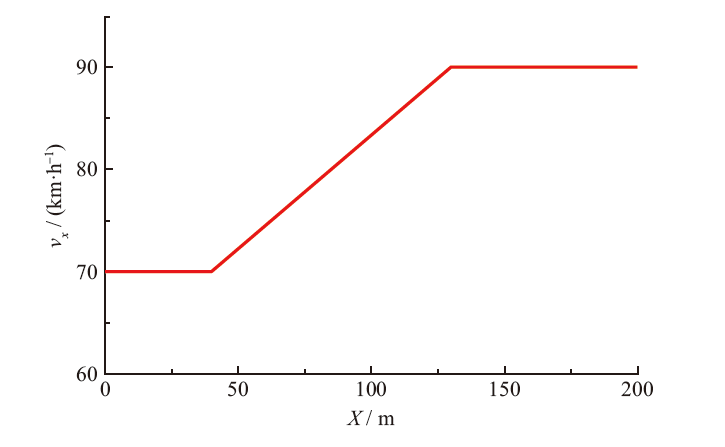
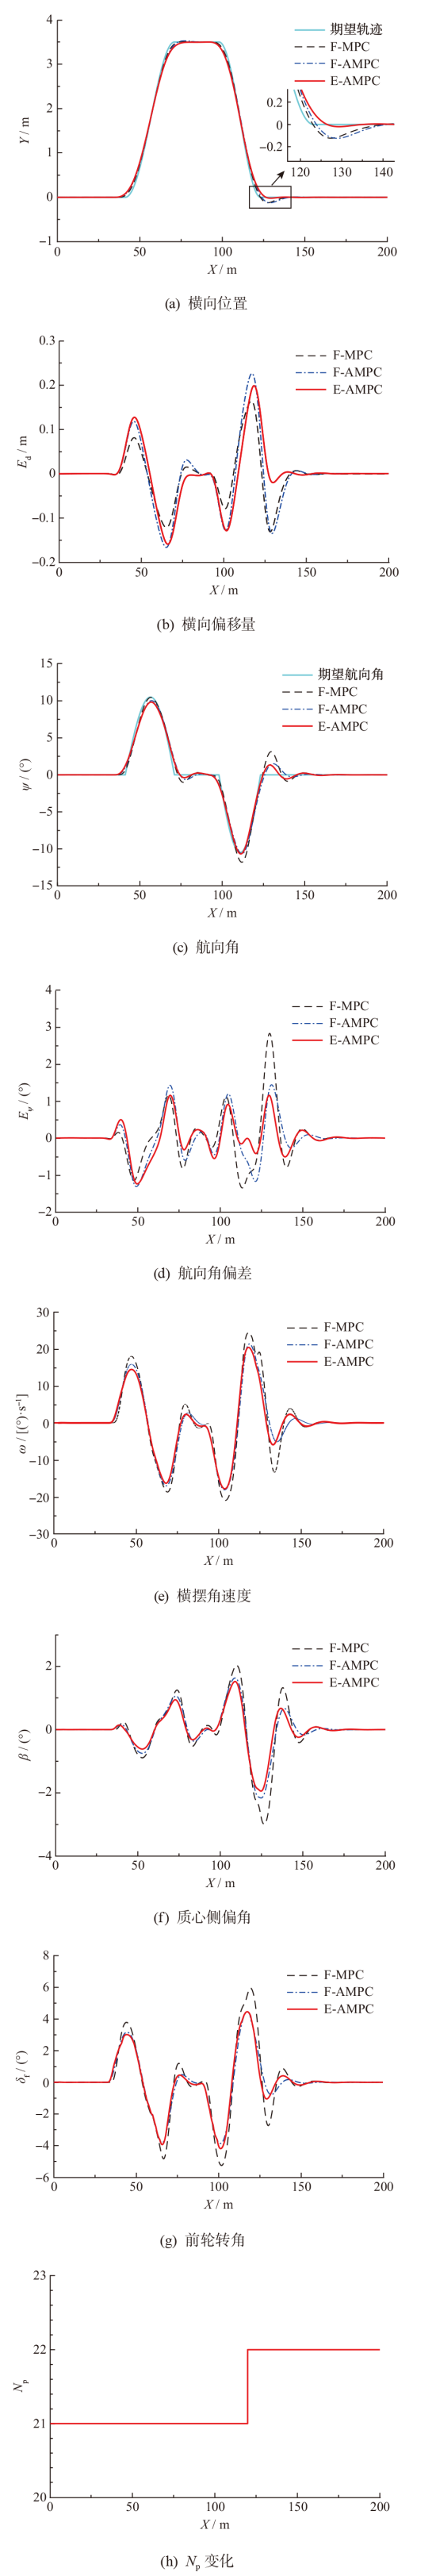
| 评价指标 | |Ed|max m | |Ed|mean m | |Eψ|max (°) | |Eψ|mean (°) | |ω|max [(°)·s-1] | |ω|mean [(°)·s-1] | |β|max (°) | |β|mean (°) |
|---|---|---|---|---|---|---|---|---|
| F-MPC | 0.164 1 | 0.030 7 | 2.838 2 | 0.341 8 | 24.414 9 | 4.656 9 | 2.990 5 | 0.389 4 |
| F-AMPC | 0.226 4 | 0.041 9 | 1.445 0 | 0.295 9 | 21.355 0 | 3.901 9 | 2.160 4 | 0.279 5 |
| E-AMPC | 0.198 7 | 0.034 6 | 1.157 9 | 0.247 4 | 20.936 3 | 3.734 0 | 1.944 0 | 0.251 8 |
| 评价指标 | |Ed|max m | |Ed|mean m | |Eψ|max (°) | |Eψ|mean (°) | |ω|max [(°)·s-1] | |ω|mean [(°)·s-1] | |β|max (°) | |β|mean (°) |
|---|---|---|---|---|---|---|---|---|
| F-MPC | 0.164 1 | 0.030 7 | 2.838 2 | 0.341 8 | 24.414 9 | 4.656 9 | 2.990 5 | 0.389 4 |
| F-AMPC | 0.226 4 | 0.041 9 | 1.445 0 | 0.295 9 | 21.355 0 | 3.901 9 | 2.160 4 | 0.279 5 |
| E-AMPC | 0.198 7 | 0.034 6 | 1.157 9 | 0.247 4 | 20.936 3 | 3.734 0 | 1.944 0 | 0.251 8 |
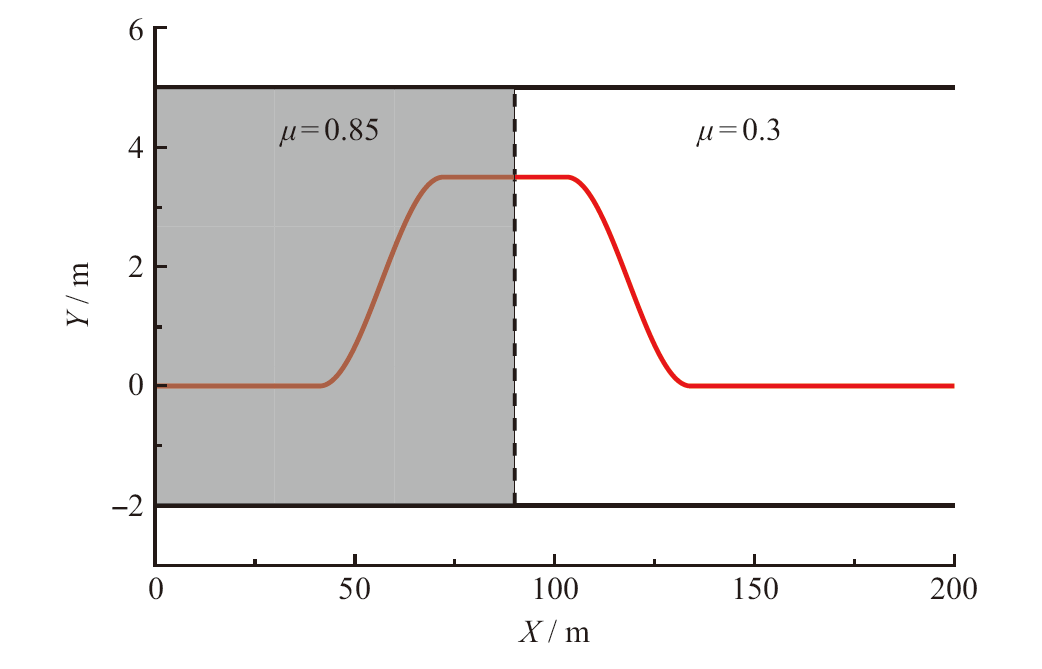
| 评价指标 | |Ed|max m | |Ed|mean m | |Eψ|max (°) | |Eψ|mean (°) | |ω|max [(°)·s-1] | |ω|mean [(°)·s-1] | |β|max (°) | |β|mean (°) |
|---|---|---|---|---|---|---|---|---|
| F-MPC | 1.205 7 | 0.164 2 | 7.371 7 | 1.280 6 | 16.226 5 | 5.415 0 | 1.636 4 | 0.284 0 |
| F-AMPC | 0.628 3 | 0.060 8 | 5.375 4 | 0.796 7 | 12.611 3 | 3.858 2 | 1.431 6 | 0.202 8 |
| E-AMPC | 0.245 4 | 0.024 8 | 1.901 3 | 0.362 2 | 13.299 1 | 2.911 6 | 1.328 2 | 0.138 0 |
| 评价指标 | |Ed|max m | |Ed|mean m | |Eψ|max (°) | |Eψ|mean (°) | |ω|max [(°)·s-1] | |ω|mean [(°)·s-1] | |β|max (°) | |β|mean (°) |
|---|---|---|---|---|---|---|---|---|
| F-MPC | 1.205 7 | 0.164 2 | 7.371 7 | 1.280 6 | 16.226 5 | 5.415 0 | 1.636 4 | 0.284 0 |
| F-AMPC | 0.628 3 | 0.060 8 | 5.375 4 | 0.796 7 | 12.611 3 | 3.858 2 | 1.431 6 | 0.202 8 |
| E-AMPC | 0.245 4 | 0.024 8 | 1.901 3 | 0.362 2 | 13.299 1 | 2.911 6 | 1.328 2 | 0.138 0 |
| [1] | WANG Huiran, WANG Qidong, CHEN Wuwei, et al. Path tracking based on model predictive control with variable predictive horizon[J]. Trans Instit Measur Contr, 2021, 43(12): 2676-2688. |
| [2] | NI Jun, HU Jibin, XIANG Changle. Envelope control for four-wheel independently actuated autonomous ground vehicle through AFS /DYC integrated control[J]. IEEE Trans Vehi Tech, 2017, 66(11): 9712-9726. |
| [3] | LU Hui, SHI Yue, HE Dengbo, et al. Model-based vehicle stability control with tyre force and instantaneous cornering stiffness estimation[J]. Proc Instit Mech Engi, Part D: J Autom Engi, 2016, 230(6): 754-770. |
| [4] | Park G. A Vehicle lateral motion control based on tire cornering stiffness estimation using in-wheel motors[J/OL]. Electronics, 2022, 11: 2589-2591. [2023-10-01] https://doi.org/10.3390/electronics11162589. |
| [5] | Rokonuzzaman M, Mohajer N, Nahavandi S, et al. Review and performance evaluation of path tracking controllers of autonomous vehicles[J]. IET Intel Transport Syst, 2021, 15(1): 646-670. |
| [6] |
WANG Hengyang, LIU Biao, PING Xianyao, et al. Path tracking control for autonomous vehicles based on an improved MPC[J]. IEEE Access. 2019, 7: 161064-161073.
doi: 10.1109/ACCESS.2019.2944894 |
| [7] | WANG Junnian, TENG Fei, LI Jing, et al. Intelligent vehicle lane change trajectory control algorithm based on weight coefficient adaptive adjustment[J]. Advan Mech Engi, 2021, 13(3): 1-16. |
| [8] | Ajorkar A, HE Y. Tuning MPC path-following controllers using multi-objective optimization[C]// Canadian Soc Mech Engi Int’l Congress. Edmonton, AB, Canada, 2022. |
| [9] | YU Hongxiao, DUAN Jianmin, Taheri S, et al. A model predictive control approach combined Unscented Kalman Filter vehicle state estimation in intelligent vehicle trajectory tracking[J]. Advan Mech Engi, 2015, 7(5): 1-14. |
| [10] | CUI Qingjia, DING Rongjun, ZHOU Bing, et al. Path tracking of an autonomous vehicle via model predictive control and nonlinear filtering[J]. Proc Instit Mech Engi, Part D: J Autom Engi, 2018, 232(9): 1237-1252. |
| [11] | CHEN Shuping, XIONG Guangming, CHEN Huiyan, et al. MPC-based path tracking with PID speed control for high-speed autonomous vehicles considering time-optimal travel[J]. J Central South University, 2020, 27(12): 3702-3720. |
| [12] | 张泽琪, 杨伟东, 贾鹏飞. 高速工况中无人驾驶车辆轨迹跟踪控制技术[J]. 中国测试, 2023, 49(10): 148-155. |
| ZHANG Zeqi, YANG Weidong, JIA Pengfei, et al. Trajectory tracking control technology for autonomous vehicles in high-speed working conditions[J]. China Measur Test Tech, 2023, 49(10): 148-155. (in Chinese) | |
| [13] | 陈志程. 智能车辆路径跟踪控制方法研究[D]. 西安: 长安大学, 2022. |
| CHEN Zhicheng. Research on intelligent vehicle path tracking control method[D]. Xi’an: Chang’an University, 2022. (in Chinese) | |
| [14] | 滕飞. 紧急避让工况智能车轨迹跟踪控制算法研究[D]. 长春: 吉林大学, 2022. |
| TENG Fei. Research on intelligent vehicle trajectory tracking control algorithm for emergency avoidance conditions[D]. Changchun: Jilin University, 2022. (in Chinese) | |
| [15] | 白国星, 孟宇, 刘立, 等. 基于可变预测时域及速度的车辆路径跟踪控制[J]. 中国机械工程, 2020, 31(11):1277-1284. |
| BAI Guoxing, MENG Yu, LIU Li, et al. Path tracking control of vehicles based on variable prediction horizon and velocity[J]. China Mech Engi, 2020, 31(11):1277-1284. (in Chinese) | |
| [16] | 刘溯奇, 王刚, 安伟彪, 等. 基于变预测时域的电动汽车轨迹跟踪控制[J]. 科学技术与工程, 2021, 21(17): 7348-7354. |
| LIU Suqi, WANG Gang, AN Weibiao et al. Trajectory tracking control of electric vehicles based on variable prediction time domain[J]. Sci Tech Engi, 2021, 21(17): 7348-7354. (in Chinese) | |
| [17] | 杜荣华, 胡鸿飞, 高凯, 等. 基于变预测时域MPC的自动驾驶汽车轨迹跟踪控制研究[J]. 机械工程学报, 2022, 58(24): 275-288. |
| DU Ronghua, HU Hongfei, GAO Kai, etc. Research on trajectory tracking control of autonomous vehicle based on variable predictive time domain MPC[J]. J Mech Engi, 2022, 58(24): 275-288. (in Chinese) | |
| [18] | ZHANG Bing, ZONG Changfu, CHEN Gongying, et al. An adaptive-prediction horizon model prediction control for path tracking in a four-wheel independent control electric vehicle[J]. Proc Institut Mech Engi, Part D: J Autom Engi, 2019, 233(12), 3246-3262. |
| [19] | MIAO Baorui, HAN Chao. Intelligent vehicle obstacle avoidance path-tracking control based on adaptive model predictive control[J]. Mech Sci, 2023, 14: 247-258. |
| [20] | 尚强, 王国权. 基于PAC2002魔术公式的轮胎动力学特性分析[J]. 北京信息科技大学学报(自然科学版), 2019, 34(6): 76-81. |
| SHANG Qiang, WANG Guoquan. Analysis of tire dynamic characteristics based on PAC2002 magic formula[J]. J Beijing Institute of Machinery, 2019, 34(6): 76-81. (in Chinese) | |
| [21] | ZHOU Hongliang, JIA Fengjiao, JING Houhua. Coordinated longitudinal and lateral motion control for four wheel independent motor-drive electric vehicle[J]. IEEE Trans Vehi Tech, 2018, 67(5): 3782-3790. |
| [22] | 麻颖俊, 郭洪艳, 陈虹, 等. 基于滑模观测器的汽车轮胎力级联估计方法[J]. 信息与控制, 2016, 45(02): 177-184. |
| MA Yingjun, GUO Hongyan, CHEN Hong, et al. A cascaded estimation method for automotive tire force based on sliding mode observer[J]. Info Contr, 2016, 45(2): 177-184. (in Chinese) | |
| [23] | 高松, 王玉琼, 王玉海, 等. 智能汽车纵横向整体反馈线性化控制[J]. 吉林大学学报(工学版), 2023, 53(3): 735-745. |
| GAO Song, WANG Yuqiong, WANG Yuhai et al. Longitudinal and lateral integrated feedback linearization control for intelligent vehicle[J]. J Jilin Unive (Engi Tech Edit), 2023, 53(3): 735-745. (in Chinese) | |
| [24] | 戴振泳. 轮毂电机驱动车辆的平顺性和操纵稳定性研究[D]. 南京: 南京航空航天大学, 2021. |
| DAI Zhenyong. Research on smoothness and handling stability of wheel hub motor driven vehicles[D]. Nanjing University of Aeronautics and Astronautics, 2021. (in Chinese) | |
| [25] | 朱国柱. 基于非线性模型预测控制的车辆自动驾驶运动控制算法研究[D]. 杭州: 浙江大学, 2023. |
| ZHU Guozhu. Research on vehicle autonomous driving motion control algorithm based on nonlinear model predictive control[D]. Hangzhou: Zhejiang University, 2023. (in Chinese) | |
| [26] |
王银, 张灏琦, 孙前来, 等. 基于自适应MPC算法的轨迹跟踪控制研究[J]. 计算机工程与应用, 2021, 57(14): 251-258.
doi: 10.3778/j.issn.1002-8331.2007-0015 |
| WANG Yin, ZHANG Haoqi, SUN Qianlai, et al. Research on trajectory tracking control based on adaptive MPC algorithm[J]. Comput Engi Appl, 2021, 57(14): 251-258. (in Chinese) | |
| [27] | 王凡勋. 分布式驱动智能电动汽车换道轨迹规划与跟踪控制研究[D]. 南京: 东南大学, 2022. |
| WANG Fanxun. Research on trajectory planning and tracking control of distributed drive intelligent electric vehicles[D]. Nanjing: Southeast University, 2022. (in Chinese) |
| [1] | WU Hangzhe, JIAO Yizhou, LIU Yang, ZHONG Wei, WANG Shuihe, GUO Jinghua, ZHAO Jian. Predictive trajectory tracking control by a linear time-varying model for emergency collision avoidance of autonomous vehicles [J]. Journal of Automotive Safety and Energy, 2025, 16(6): 934-944. |
| [2] | ZHENG Xunjia, CAO Zeyi, CHEN Xing, LIU Hui, GAO Jianjie. Trajectory tracking control based on adaptive prediction time-domain MPC [J]. Journal of Automotive Safety and Energy, 2025, 16(5): 773-783. |
| [3] | GAO Chaojun, LI Yicheng, CAI Yingfeng, WANG Hai, JIANG Jin. Research on AEB control of autonomous vehicles based on sensor fusion perception [J]. Journal of Automotive Safety and Energy, 2025, 16(4): 629-637. |
| [4] | WANG Lin, CHEN Qinghua, YE Hongling, WANG Pengfei, XU Chi, QIAN Aiwen. Simulation of intelligent vehicle trajectory tracking based on neural network adaptive MPC [J]. Journal of Automotive Safety and Energy, 2025, 16(4): 638-647. |
| [5] | LI Yi, LIU Xiangui, TANG Yaohong, CHEN Lipei, CHEN Yangrui, YOU Mingxian. Safety stability and tracking control strategy for robobus under variable curvature roads [J]. Journal of Automotive Safety and Energy, 2025, 16(1): 136-147. |
| [6] | YIN Yanli, WANG Fuzhen, ZHAN Sen, HUANG Xuejiang, ZHANG Xinxin, ZHANG Fuchun. Hierarchical control for hybrid electric vehicle platoon based on KL divergence working condition recognition [J]. Journal of Automotive Safety and Energy, 2024, 15(2): 242-252. |
| [7] | LI Zhiwen, JIAO Xiaohong, ZHANG Ting. FWID EV robust weighted gain-scheduling trajectory tracking control based on polytope system [J]. Journal of Automotive Safety and Energy, 2024, 15(1): 111-120. |
| [8] | ZHAO Chongqin, JING Hui, WANG Gang, FENG Huanqin, LIU Fuyun. Lane-keeping control for commercial vehicles with an MPC algorithm considering parameter estimation [J]. Journal of Automotive Safety and Energy, 2024, 15(1): 129-136. |
| [9] | LI Wenli, XIAO Kaiwen, REN Yongpeng, LI Chao, Yi Fan. Path planning and control method for vehicle obstacle avoidance in pedestrian crossing scenes [J]. Journal of Automotive Safety and Energy, 2022, 13(3): 489-501. |
| [10] | ZHAO Shuen, CHEN Wenbin, DENG Zhaoxue, LIU Wei. Trajectory tracking control for intelligent vehicles driving in curved road based on expanded state observers [J]. Journal of Automotive Safety and Energy, 2022, 13(1): 112-121. |
| [11] | LI Yaohua, FAN Jikang, LIU Yang, HE Jie, LI Zetian, PAN Shaofei. Path planning and path tracking control for autonomous vehicle based on MPC with adaptive dual-horizon-parameters [J]. Journal of Automotive Safety and Energy, 2021, 12(4): 528-539. |
| [12] | LI Lei, LI Jun, ZHANG Shiyi. Trajectory tracking control of autonomous vehicles with optimized sliding mode control [J]. Journal of Automotive Safety and Energy, 2020, 11(4): 503-510. |
| [13] | YANG Echuan, XIE Chuanren, WANG Jiang, CHEN Ruinan, OU Jian . Active anti-roll control method for a semi-trailer based on MPC theory [J]. Journal Of Automotive Safety And Energy, 2020, 11(1): 61-70. |
| [14] | XIE Hui, LIU Shuangshuang . Lateral and longitudinal motion control of unmanned vehicles using model predictive control [J]. Journal Of Automotive Safety And Energy, 2019, 10(3): 326-333. |
| [15] | HU Yuanzhi, DING Xiaomu, LIU Xi, LI Hao . Research on full speed range adaptive cruise control [J]. Journal Of Automotive Safety And Energy, 2019, 10(3): 357-365. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
