Welcome to Journal of Automotive Safety and Energy,

Journal of Automotive Safety and Energy ›› 2024, Vol. 15 ›› Issue (5): 753-762.DOI: 10.3969/j.issn.1674-8484.2024.05.013
• Intelligent Driving and Intelligent Transportation • Previous Articles Next Articles
HUANG Chen1,2( ), JIA Dingpeng1, SUN Xiaoqiang1, XU Qing2
Received:2023-11-01
Revised:2024-06-10
Online:2024-10-31
Published:2024-11-07
CLC Number:
HUANG Chen, JIA Dingpeng, SUN Xiaoqiang, XU Qing. Intelligent vehicle path planning method based on peripheral vehicle trajectory prediction[J]. Journal of Automotive Safety and Energy, 2024, 15(5): 753-762.
Add to citation manager EndNote|Ris|BibTeX
URL: https://www.journalase.com/EN/10.3969/j.issn.1674-8484.2024.05.013
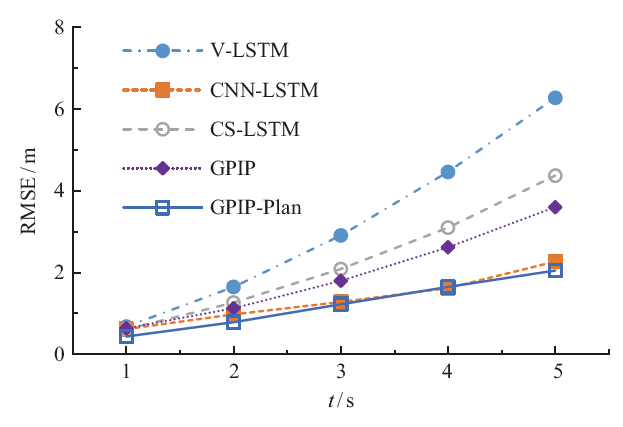
| 预测时 间/ s | 预测精度 / m | ||||
|---|---|---|---|---|---|
| V-LSTM | CNN-LSTM | CS-LSTM | GPIP | GPIP-Plan | |
| 1 | 0.68 | 0.621 | 0.61 | 0.64 | 0.44 |
| 2 | 1.65 | 0.98 | 1.27 | 1.13 | 0.79 |
| 3 | 2.91 | 1.28 | 2.09 | 1.80 | 1.23 |
| 4 | 4.46 | 1.62 | 3.10 | 2.62 | 1.65 |
| 5 | 6.27 | 2.27 | 4.37 | 3.60 | 2.05 |
| 预测时 间/ s | 预测精度 / m | ||||
|---|---|---|---|---|---|
| V-LSTM | CNN-LSTM | CS-LSTM | GPIP | GPIP-Plan | |
| 1 | 0.68 | 0.621 | 0.61 | 0.64 | 0.44 |
| 2 | 1.65 | 0.98 | 1.27 | 1.13 | 0.79 |
| 3 | 2.91 | 1.28 | 2.09 | 1.80 | 1.23 |
| 4 | 4.46 | 1.62 | 3.10 | 2.62 | 1.65 |
| 5 | 6.27 | 2.27 | 4.37 | 3.60 | 2.05 |
| 算法 | 场景 | 曲率/ 10-4 | 前轮转角/ 10-2 | |||
|---|---|---|---|---|---|---|
| 最大 | 平均 | 最大 | 平均 | |||
| APF | 邻车切入 | 28.0 | 6.5 | 6.0 | 1.3 | |
| 多车共行 | 6.0 | 1.5 | 2.1 | 2.6 | ||
| S型弯曲道路 | 76.0 | 36.0 | 47.0 | 18.0 | ||
| APF+ GPIP-plan | 邻车切入 | 43.0 | 5.6 | 3.9 | 1.0 | |
| 多车共行 | 6.3 | 1.5 | 2.0 | 1.3 | ||
| S型弯曲道路 | 70.0 | 24.0 | 42.0 | 13.0 | ||
| 算法 | 场景 | 曲率/ 10-4 | 前轮转角/ 10-2 | |||
|---|---|---|---|---|---|---|
| 最大 | 平均 | 最大 | 平均 | |||
| APF | 邻车切入 | 28.0 | 6.5 | 6.0 | 1.3 | |
| 多车共行 | 6.0 | 1.5 | 2.1 | 2.6 | ||
| S型弯曲道路 | 76.0 | 36.0 | 47.0 | 18.0 | ||
| APF+ GPIP-plan | 邻车切入 | 43.0 | 5.6 | 3.9 | 1.0 | |
| 多车共行 | 6.3 | 1.5 | 2.0 | 1.3 | ||
| S型弯曲道路 | 70.0 | 24.0 | 42.0 | 13.0 | ||
| [1] | 蔡英凤, 朱南楠, 邰康盛, 等. 基于注意力机制的车辆行为预测[J]. 江苏大学学报(自然科学版), 2020, 41(2): 125-130. |
| CAI Yifeng, ZHU Nannan, TAI Kangsheng, et al. Vehicle behaviour prediction based on attention mechanism[J]. J Jiangsu Univ (Nat Sci Ed), 2020, 41(2): 125-130. (in Chinese) | |
| [2] | ZHANG Lei, XIAO Wei, ZHANG Zhi, et al. Surrounding vehicles motion prediction for risk assessment and motion planning of autonomous vehicle in highway scenarios[J]. IEEE Access, 2020, 8: 209356-209376. |
| [3] | 宗长富, 王畅, 何磊, 等. 基于双层隐式马尔科夫模型的驾驶意图辨识[J]. 汽车工程, 2011 (8): 701-706. |
| ZONG Changfu, WANG Chang, HE Lei, et al. Driving intention recognition based on double-layer hidden Markov model[J]. Autom Engineering, 2011, 43(8): 701-706. (in Chinese) | |
| [4] | GUO Hongyan, MENG Qingyu, GAO Dongpu, et al. Vehicle trajectory prediction method coupled with ego vehicle motion trend under dual attention mechanism[J]. IEEE Trans Instru Meas, 71: 1-16, 2022. |
| [5] | 李文礼, 韩迪, 任勇鹏, 等. 基于交互车辆轨迹预测的自动驾驶车辆轨迹规划[J]. 计算机应用研究, 2023, 40(2): 519-525, 538. |
| LI Wenli, HAN Di, REN Yongpeng, et al. Trajectory planning of autonomous vehicles based on interactive vehicle trajectory prediction[J]. App Res Comput, 2023, 40(2): 519-525, 538. (in Chinese) | |
| [6] | 李旭川. 多车环境下的无人驾驶汽车换道轨迹规划方法研究[D]. 西安: 长安大学, 2021. |
| LI Xuchuan. Research on lane change trajectory planning method for driverless cars in multi-vehicle environment[D]. Xi'an: Chang'an University, 2021. (in Chinese) | |
| [7] |
刘启冉, 连静, 陈实, 等. 考虑交互轨迹预测的自动驾驶运动规划算法[J]. 东北大学学报(自然科学版), 2022, 43(7): 930-936.
doi: 10.12068/j.issn.1005-3026.2022.07.003 |
| LIU Qiran, LIAN Jing, CHEN Shi, et al. Automatic driving motion planning algorithm considering interaction trajectory prediction[J]. J Northeast Univ (Nat Sci Ed), 2022, 43(7): 930-936. (in Chinese) | |
| [8] | 王安杰, 郑玲, 李以农, 等. 基于预测风险场的智能汽车主动避撞运动规划[J]. 汽车工程, 2021, 43(7): 1096-1104. |
| WANG Anjie, ZHENG Ling, LI Yinong, et al. Active collision avoidance motion planning for intelligent vehicles based on predicted risk fields[J]. Automotive Engineering, 2021, 43(7): 1096-1104. (in Chinese) | |
| [9] | MO Xiaoyu, YANG Xing, LV Chen. Graph and recurrent neural network-based vehicle trajectory prediction for highway driving[C]// 2021 IEEE Int’l Intell Transp Syst Conf (ITSC), 2021: 1934-1939. |
| [10] | WU Qingquan, LU Yingjun, LIU Xiangqiang. Real-Time globally optimized path planning in a dynamic environment combing artificial potential field and fuzzy neural network[C]// 2016 13th Int’l Compu Conf Wavelet Active Media Tech Info Proc (ICCWAMTIP), IEEE, 2016: 114-118. |
| [11] | 张家旭, 王晨, 赵健. 基于改进人工势场法的汽车弯道超车路径规划与跟踪控制[J]. 汽车工程, 2021, 43(4): 546-552. |
| ZHANG Jiaxu, WANG Chen, ZHAO Jian. Path planning and tracking control of automobile curve overtaking based on improved artificial potential field method[J]. Automotive Engineering, 2021, 43(4): 546-552. (in Chinese) | |
| [12] |
罗玉涛, 石紫娴, 梁伟强. 基于改进人工势场的无人驾驶动态规划算法研究[J]. 中国公路学报, 2022, 35(12): 279-292.
doi: 10.19721/j.cnki.1001-7372.2022.12.022 |
| LUO Yutao, SHI Zixian, LIANG Weiqiang. Research on unmanned dynamic planning algorithm based on improved artificial potential field[J]. Chin J Highw, 2022, 35(12): 279-292. (in Chinese) | |
| [13] |
王其东, 魏振亚, 陈无畏, 等. 基于参数时变人工势场的车道保持协调控制[J]. 机械工程学报, 2018, 54(18): 105-114.
doi: 10.3901/JME.2018.18.105 |
| WANG Qidong, WEI Zhenya, CHEN Wuwei, et al. Coordinated control of lane keeping based on parametric time-varying artificial potential field[J]. J Mech Engineering, 2018, 54(18): 105-114. (in Chinese) | |
| [14] | Kim ByeoungDo, Chang Mook Kang, Jaekyum Kim, et al. Probabilistic vehicle trajectory prediction over occupancy grid map via recurrent neural network[C]// 2017 IEEE 20th Int’l Conf Intel Transp Syst (ITSC), 2017: 399-404. |
| [15] | Nachiket D, Mohan M. Convolutional social pooling for vehicle trajectory prediction[C] // Proc IEEE Conf Comp Vision Pattern Recog Workshop, 2018: 1468-1476. |
| [16] | XIE Guo, SHANGGUAN Anqi, FEI Rong, et al. Motion trajectory prediction based on a CNN-LSTM sequential model[J]. Sci China Info Sci, 2020, 63: 1-21. |
| [17] | 李胜琴, 丁雪梅. 基于五次多项式的自动驾驶汽车辆轨迹规划[J]. 江苏大学学报(自然科学版), 2023, 44(4): 392-398. |
| LI Shengqin, DING Xuemei. Intelligent vehicle trajectory planning based on fifth-degree polynomials[J]. J Jiangsu Univ (Nat Sci Ed), 2023, 44(4): 392-398. (in Chinese) |
| [1] | WANG Yue, DUAN Hongwei, ZHONG Wei, YANG Lu, HE Lei, CHAI Fulai, SHI Xiaoyang. Path planning method for leader-follower multi-vehicle formation with integrating GoT-SAC [J]. Journal of Automotive Safety and Energy, 2026, 17(1): 122-129. |
| [2] | YANG Zongru, HU Yunze, LIU Shiqi, GUAN Yang, WU Wei, LIU Chang. Distributed active perception path planning for the estimation of parking occupancy status [J]. Journal of Automotive Safety and Energy, 2026, 17(1): 140-148. |
| [3] | ZHAO Jian, GONG Jue, FAN Kefeng, LIU Pengbo, LI Linhui, WANG Xiang, XU Zheng, DONG Zeyuan, YAO Nianmin. Safety and protection technologies for intelligent vehicles with strongly coupled structural, functional and information domains [J]. Journal of Automotive Safety and Energy, 2025, 16(6): 813-831. |
| [4] | ZHANG Bingli, ZHANG Zhisen, ZHANG Yangyang, LIU An, XU Yonghua. BI-RRT* path planning method based on GA optimization and path extension heuristic sampling [J]. Journal of Automotive Safety and Energy, 2025, 16(6): 923-933. |
| [5] | PENG Qianlong, JIN bieshu, WANG Jianqiang, WANG Guangwei. Skeleton guided hierarchical autonomous valet parking path planning method with lane constraints [J]. Journal of Automotive Safety and Energy, 2025, 16(5): 784-792. |
| [6] | LI Shunming, WANG Changrong, SHI Wenbei. Progress of mobile charging robot for photovoltaic energy storage and charging [J]. Journal of Automotive Safety and Energy, 2025, 16(4): 505-520. |
| [7] | CHENG Rui, LU Chuncheng, YUAN Quan, CUI Tao, To. Jeremy, WANG Tao. Evaluation on the complexity of scenarios for VRU on urban roads based on self-organizing K-means [J]. Journal of Automotive Safety and Energy, 2025, 16(3): 386-395. |
| [8] | CHEN Xiaofeng, WANG Lanwen, MA Guo, ZHANG Lei, BAO Jiading, JING Hui. Energy and stability aware path planning for autonomous vehicles in off road environments [J]. Journal of Automotive Safety and Energy, 2025, 16(3): 496-503. |
| [9] | WANG Zhenyu, YU Zhuoping, TIAN Wei, XIONG Lu, LI Zhuoren. Trajectory generation algorithm for simulated vehicles based on trajectory prediction models [J]. Journal of Automotive Safety and Energy, 2025, 16(2): 286-293. |
| [10] | KUANG Xinghong, SHEN Jiacheng. Improved Northern Goshawk Optimization Algorithm and its application in intelligent vehicle path planning [J]. Journal of Automotive Safety and Energy, 2025, 16(1): 148-158. |
| [11] | QIN Yaqin, DONG Shuai, XIE Jiming, CHEN Liang, LIU Yonghua, GUO Miao. Methods for predicting vehicle trajectories in motorway weaving zones based on driving risk fields [J]. Journal of Automotive Safety and Energy, 2024, 15(6): 952-961. |
| [12] | HUANG Zheng, WANG Hongxing, DU Biao, GAO Song, GAO Feng. Intelligent inspection method for power transmission towers, substations, and distribution poles using fixed UAV nests [J]. Journal of Automotive Safety and Energy, 2024, 15(5): 670-679. |
| [13] | SHI Tianjing, LI Xu. Traffic flow parameter prediction method based on dynamic graphs self-attention [J]. Journal of Automotive Safety and Energy, 2024, 15(5): 680-688. |
| [14] | QU Guangyue, YANG Lan, YUAN Meng, FANG Shan, LIU Songyan. A multimodal trajectory prediction method of pedestrians at signalized intersections for autonomous vehicles [J]. Journal of Automotive Safety and Energy, 2024, 15(5): 689-701. |
| [15] | LI Yulong, XIE Hui, SONG Kang. An obstacle avoidance path planning algorithm for autonomous buses based on tracking error observation and target measurement error observation [J]. Journal of Automotive Safety and Energy, 2024, 15(4): 579-590. |
| Viewed | ||||||
|
Full text |
|
|||||
|
Abstract |
|
|||||
